Products · MANUS
MANUS Metagloves
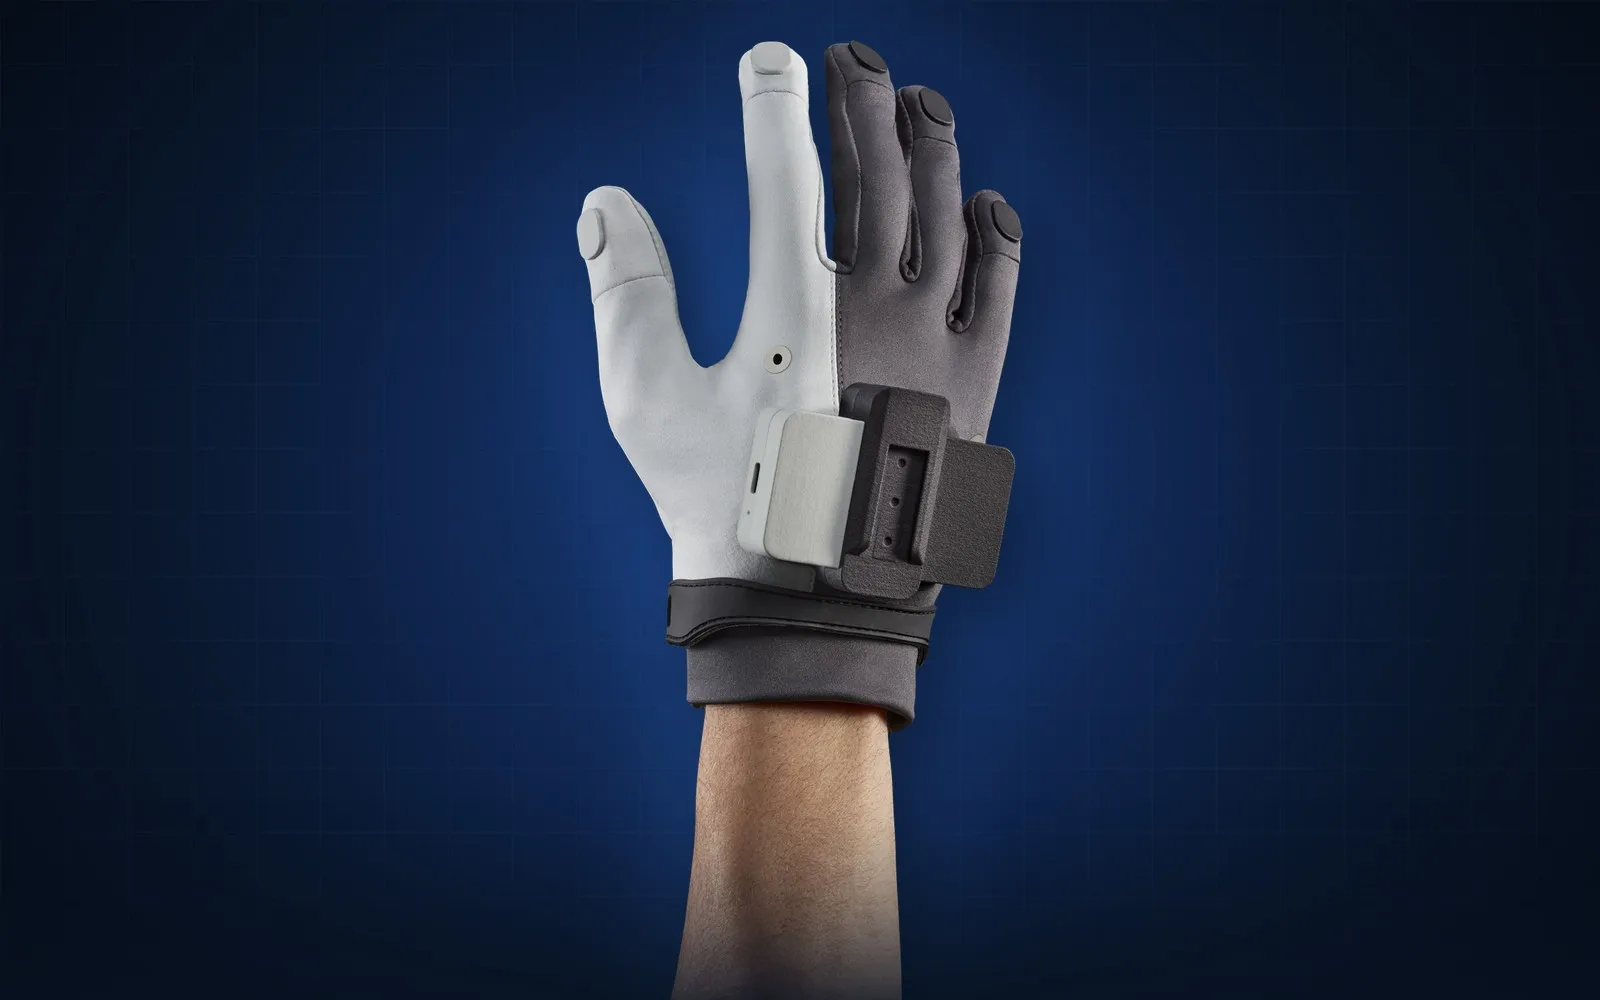
Data gloves that track every joint of the hand without cameras. The official data glove for NVIDIA Isaac Teleop, used for robot teleoperation, demonstration data collection and motion capture.
- 25 DoF per hand
- No occlusion, no drift
- NVIDIA Isaac Teleop
- full anatomical hand per glove
- 25 DoF
- sampling rate
- 120 Hz
- tracking latency, wired (50 ms wireless)
- 30 ms
- per battery, swappable for all-day use
- 3 h
- wireless range over Bluetooth 5.0
- 15 m
Models
Two models, one platform
Both gloves track the full hand the same way. Pro Haptic adds a vibration motor on every fingertip, so the operator feels when the robot hand makes contact.
| Metagloves ProSimulated teleoperation, teaching and data collection | Metagloves Pro HapticDriving real robot hands where contact matters | |
|---|---|---|
| Fingertip sensors | 5 electromagnetic (EMF) sensors, 6 DoF each | 5 electromagnetic (EMF) sensors, 6 DoF each |
| Hand model | Full anatomical hand, 25 DoF | Full anatomical hand, 25 DoF |
| Sampling rate | 120 Hz | 120 Hz |
| Tracking latency | 30 ms wired · 50 ms wireless | 30 ms wired · 50 ms wireless |
| Haptic feedback | — | 5 vibration motors (LRA), 256 levels per finger; 4 ms wired · 16 ms wireless |
| Weight (size M) | 167 g | 178 g |
| Battery | Swappable, up to 3 h; ~2 h to charge over USB-C | Swappable, up to 3 h; ~2 h to charge over USB-C |
| Connection | USB-C, or Bluetooth 5.0 via wireless dongle (up to 15 m) | USB-C, or Bluetooth 5.0 via wireless dongle (up to 15 m) |
| Software | MANUS Core 3 and Hand Solver 3 | MANUS Core 3.1 or newer and Hand Solver 3 |
Specifications from MANUS. Quantum Metagloves are a legacy model and no longer sold.
Why gloves
Why gloves for robot data
Dexterous robot policies learn from human demonstrations. The cleaner the finger data, the better the robot learns.
| Joint | MCP | PIP | DIP | Robot cmd |
|---|---|---|---|---|
| Thumb | 34.8° | 43.8° | 24.7° | 0.367 |
| Index | 38.4° | 48.3° | 27.2° | 0.400 |
| Middle | 25.7° | 32.3° | 18.2° | 0.267 |
| Ring | 15.0° | 18.8° | 10.6° | 0.133 |
| Little | 7.2° | 9.0° | 5.1° | 0.067 |
No occlusion
Sensors sit on the fingertips and use electromagnetic tracking, so fingers hidden behind a grasped object are still measured. Camera tracking loses them exactly when the data matters.
No drift
Finger positions do not wander over long recording sessions, so the hundredth demonstration is as clean as the first.
Fast calibration
A four-step calibration takes about 50 seconds. Profiles are saved, so there is no recalibration between sessions, users or battery swaps.
Robot-ready output
MANUS Core outputs both the operator's hand skeleton and a retargeted skeleton, ready to map onto a robot hand's joints.
NVIDIA Isaac
The official glove for Isaac Teleop
At GTC 2026 NVIDIA brought Isaac Teleop to general availability, a framework for teleoperation and data collection in simulation and on real robots. MANUS is its officially supported data glove, and is supported in Isaac Lab.
Robotics
- NVIDIA Isaac Teleop
- NVIDIA Isaac Lab
- ROS 2
- MANUS SDK
Motion capture
- Xsens MVN
- OptiTrack Motive
- Vicon Shogun
- Qualisys QTM
3D and engines
- Unity
- Unreal Engine
- MotionBuilder
- Blender
- Houdini
- 3ds Max
XR
- OpenXR
- SteamVR
- VRED
In the box
What comes with a pair
Metagloves Pro Haptic. All electronics sit in a detachable top module, so several users can share one set of electronics with their own sized gloves.
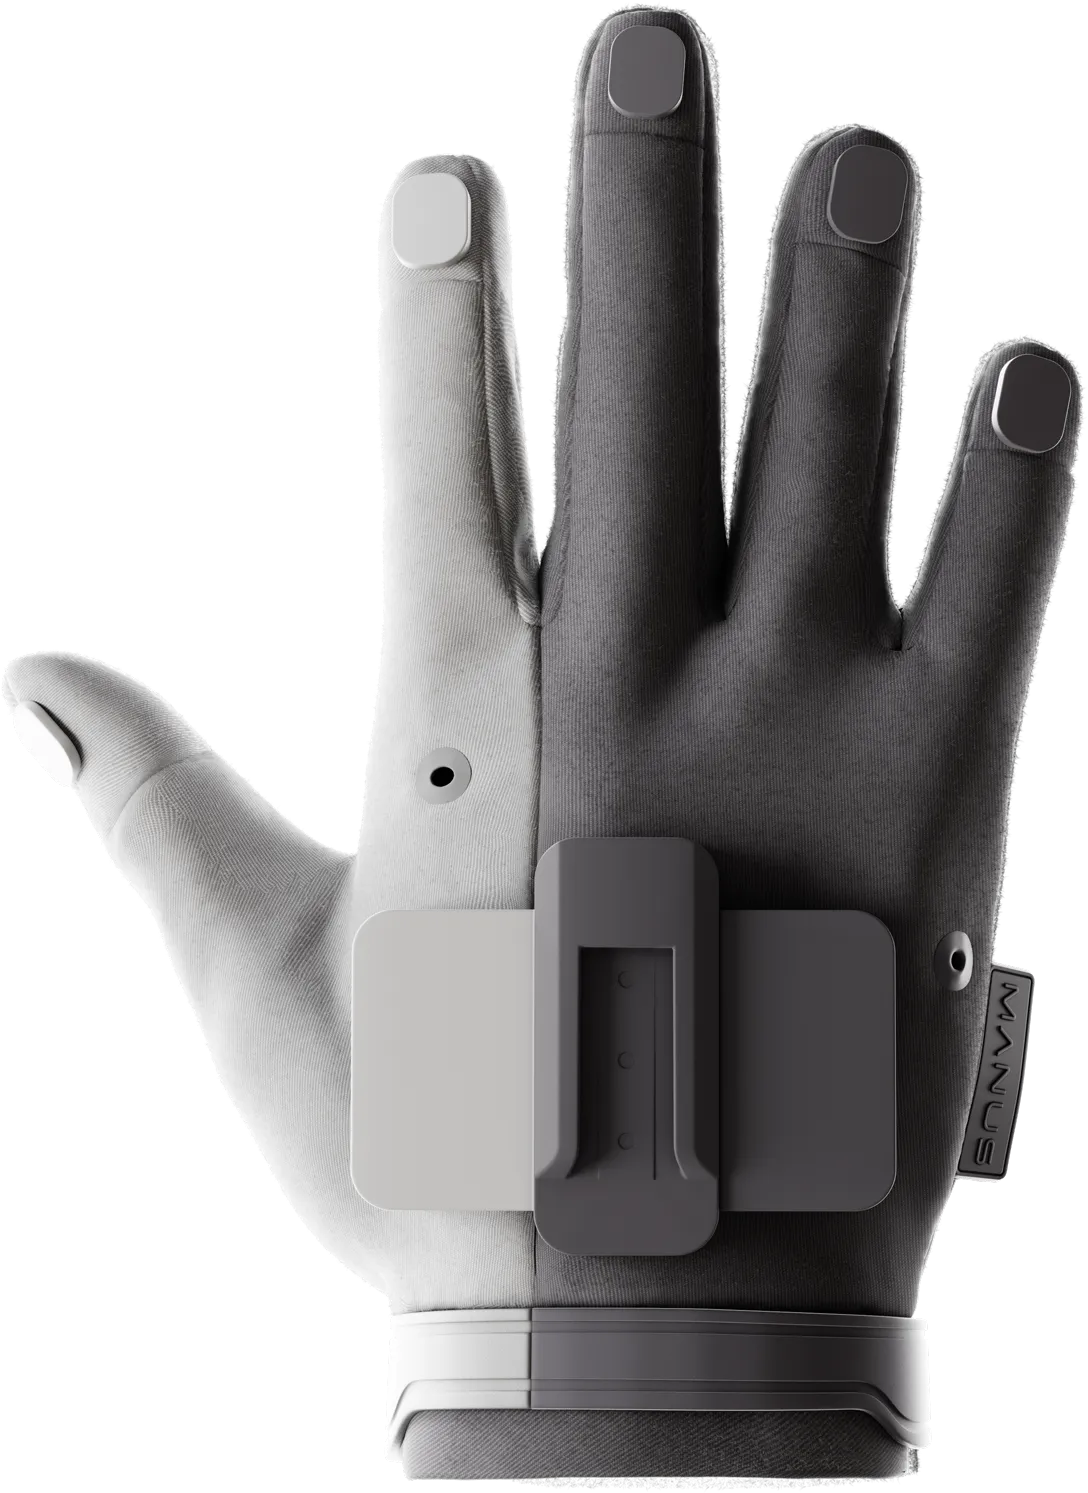
- Pair of gloves (sizes M or L)
- Pair of detachable top modules with all electronics
- Wireless dongle
- Two swappable batteries
- Two USB-C cables
- Quick-start guide and travel case
From Aedu
Buying from Aedu includes
Set up on your workstation
MANUS Core installed and licensed, gloves paired and calibrated for each operator.
Connected to your robot stack
A working example in ROS 2 or NVIDIA Isaac Lab, so your team starts from a running pipeline.
Mapped to your robot hand
Help retargeting glove data to your hand's joint count and limits.
Local support
Training for operators, and the two-year manufacturer warranty handled with us locally.
FAQ
Questions we get
Which model should we choose?
Metagloves Pro for simulated teleoperation, teaching and data collection. Metagloves Pro Haptic when operators drive a real robot hand and need to feel contact. Both track the hand the same way.
Do the gloves work with NVIDIA Isaac?
Yes. MANUS is the officially supported data glove in NVIDIA Isaac Teleop and is supported in Isaac Lab. The gloves also stream to ROS 2 through the MANUS SDK.
Can several people share one pair?
Yes. The electronics sit in a detachable top module, so users can share one set of electronics with their own sized gloves. Calibration profiles are saved per user.
How long do the batteries last?
Up to 3 hours per battery, with about 2 hours to charge over USB-C. Batteries swap in seconds, and the gloves can also run on external USB-C power for all-day sessions.
Work with us
Tell us how many operators, which robot hand and whether you need haptics, and we will reply by email with a quote.